 https://doi.org/10.4081/jae.2021.1090
The design of a force feedback soft gripper for tomato harvesting
All claims expressed in this article are solely those of the authors and do not necessarily represent those of their affiliated organizations, or those of the publisher, the editors and the reviewers. Any product that may be evaluated in this article or claim that may be made by its manufacturer is not guaranteed or endorsed by the publisher.
Published: 18 March 2021
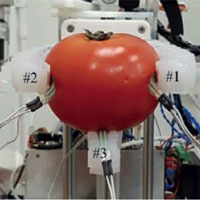
In smart farming, both artificial intelligence and robotic systems are applied in order to improve efficiency. In agriculture, for jobs such as seeding, monitoring, and harvesting, robots are widely used. When using robots to harvest fruit and vegetables, it is essential not to apply excessive force, as it may damage the harvest. In this paper, a soft robotic three-fingered gripper is presented. It was designed and analysed using the finite element method. Each finger is made of silicone rubber. The shape of the finger is designed so that it is capable of handling spherical shaped objects, such as tomatoes or oranges. When holding a tomato, the fingers apply the contact force. The fingers are actuated pneumatically and the force applied is also controlled by a micro controller. The pressure inside the air chamber of the finger is in the range of 0- 95 kPa. Force sensors are attached to the end of each finger to provide force feedback. Then, the holding force is adjusted and applied to the surface of the tomato. The gripper can successfully grasp tomatoes with a force less than the bio-yield of the tomatoes 2.57 N.
Downloads
Bernardi L., Hopf R., Ferrari A., Ehret A.E., Mazza E. 2017. On the large strain deformation behavior of silicone-based elastomers for biomedical applications. Polym. Test. 58:189-98. DOI: https://doi.org/10.1016/j.polymertesting.2016.12.029
Brown E., Rodenberg N., Amend J., Mozeika A., Steltz E., Zakin M. R., Lipson H., Jaeger H.M. 2010. Universal robotic gripper based on the jamming of granular material. Proc. Natl. Acad. Sci. 107:18809-14. DOI: https://doi.org/10.1073/pnas.1003250107
Hao Y., Liu Z., Liu J., Fang X., Fang B., Nie S., Guan Y., Sun F., Wang T., Wen L. 2020. A soft gripper with programmable effective length, tactile and curvature sensory feedback. Smart Mater. Struct. 29:035006.
Hayashi S., Ganno K., Ishii Y., Tanaka I. 2002. Robotic harvesting system for eggplants. JARQ. 36:163-68. DOI: https://doi.org/10.6090/jarq.36.163
Ji C., Zhang J., Yuan T. , Li W. 2014. Research on key technology of truss tomato harvesting robot in greenhouse. Appl. Mech. Mater. 442:480-86.
Jinliang G., Zhao D., Wei J., Wu X. 2010. Design and control of the open apple-picking-robot manipulator. pp 5-8 in 3rd Int. Conf. Comp. Sci. Info. Tech., Chengdu, China. DOI: https://doi.org/10.1109/ICCSIT.2010.5564770
Lehnert C., English A., McCool C., Tow A.W., Perez T. 2017. Autonomous sweet pepper harvesting for protected cropping systems. IEEE Rob. Autom. Lett. 2:872-9. DOI: https://doi.org/10.1109/LRA.2017.2655622
Liu J., Li P., Li Z. 2007. A multi-sensory end-effector for spherical fruit harvesting robot. pp 258-62 in IEEE Int. Conf. Autom. Logist., Jinan, China. DOI: https://doi.org/10.1109/ICAL.2007.4338567
Liu J., Li Z., Wang F., Li P., Xi N. 2013. Hand-arm coordination for a tomato harvesting robot based on commercial manipulator. pp 2716-20 in IEEE Int. Conf. Rob. Biomimetics, Shenzhen, China. DOI: https://doi.org/10.1109/ROBIO.2013.6739884
Monta M., Kondo N., Ting K.C. 1998. End-effectors for tomato harvesting robot. J. Artif. Intell. Rev. 12:11-25. DOI: https://doi.org/10.1023/A:1006595416751
Mosadegh B., Polygerinos P., Keplinger C., Wennstedt S., Shepherd R.F., Gupta U., Shim J., Bertoldi K., Walsh C.J., Whitesides G.M. 2014. Soft robotics: pneumatic networks for soft robotics that actuate rapidly. Adv. Funct. Mater 24:2109. DOI: https://doi.org/10.1002/adfm.201470092
Sirisomboon P., Tanaka M., Kojima T. 2012. Evaluation of tomato textural mechanical properties. J. Food Eng. 111:618-24. DOI: https://doi.org/10.1016/j.jfoodeng.2012.03.007
Truby R.L., Wehner M., Grosskopf A.K., Vogt D.M., Uzel S.G.M., Wood R.J., Lewis J.A. 2018. Soft somatosensitive actuators via embedded 3D printing. Adv. Mater. 30:1706383. DOI: https://doi.org/10.1002/adma.201706383
van Henten E.J., Hemming J., van Tuijl B.A.J., Kornet J.G., Meuleman J., Bontsema J., van Os E.A. 2002. An autonomous robot for harvesting cucumbers in greenhouses. Auton. Rob. 13:241-58. DOI: https://doi.org/10.1023/A:1020568125418
Wang G., Yu Y., Feng Q. 2016. Design of end-effector for tomato robotic harvesting. IFAC-Papers OnLine 49:190-3. DOI: https://doi.org/10.1016/j.ifacol.2016.10.035
Wang Z., Zhu M., Kawamura S., Hirai S. 2017. Comparison of different soft grippers for lunch box packaging. Rob. Biomimet. 4:10. DOI: https://doi.org/10.1186/s40638-017-0067-1
How to Cite

This work is licensed under a Creative Commons Attribution-NonCommercial 4.0 International License.
PAGEPress has chosen to apply the Creative Commons Attribution NonCommercial 4.0 International License (CC BY-NC 4.0) to all manuscripts to be published.